01 — WHAT COMES OUT
The engine and everything attached
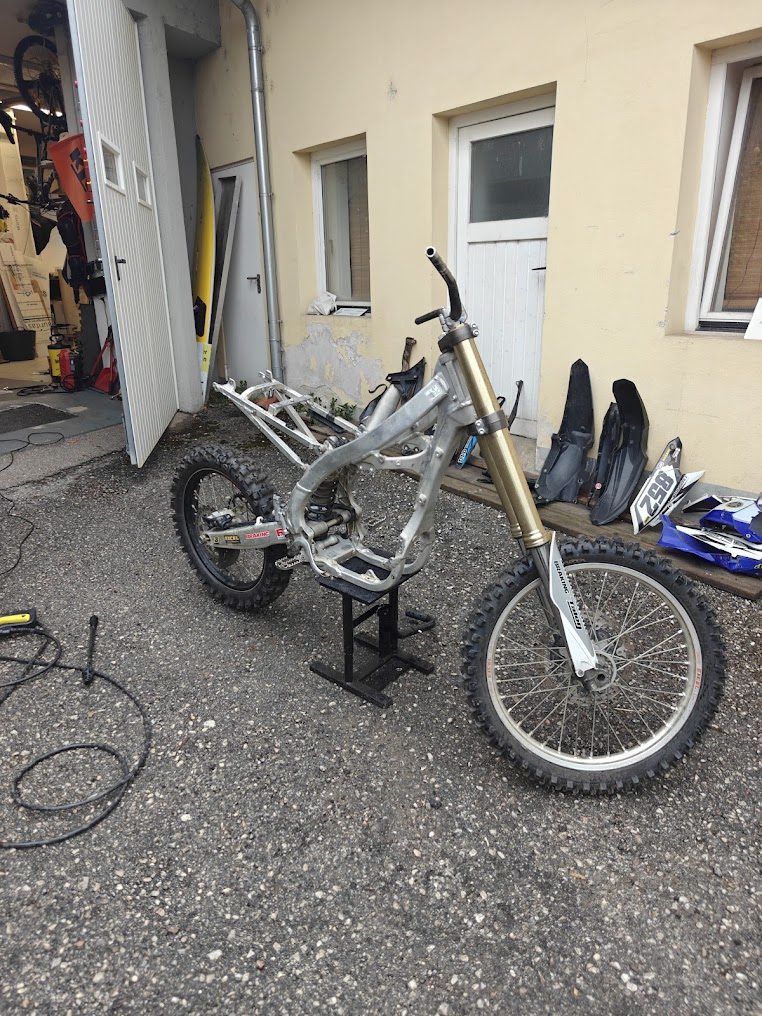
The complete combustion engine including tank, exhaust and all related components is removed. What remains is a proven chassis with free installation space.
Diploma thesis · School year 2026/27 · HTL Wien 3 Rennweg
A motocross bike with a broken combustion engine usually ends up at the scrapyard. We are turning ours into a fully electric dirt bike – with a drivetrain we specify ourselves, a battery pack we build ourselves and our own control software. Three students of mechatronics, one school year, one vehicle.
The idea
A used motocross bike, fully functional except for its engine, is the ideal starting point. Instead of scrapping it, we remove the classic drivetrain and bring the vehicle back to life electrically.
01 — WHAT COMES OUT
The complete combustion engine including tank, exhaust and all related components is removed. What remains is a proven chassis with free installation space.
02 — WHAT GOES IN
A powerful electric motor, a battery pack with a battery management system and a matching motor controller. Specified, designed and built by us.
03 — WHAT STAYS
Frame, swingarm, suspension, brakes and the entire periphery stay largely untouched. That saves effort where production engineering is already mature.
The result
The result is an emission-free, quiet and low-maintenance electric motocross bike. No fuel mix, no exhaust, no oil changes – but the ride a motocrosser is built for. A microcontroller-based control system with riding modes, GPS and crash detection completes the drivetrain.
The thesis is written in the Department of Mechatronics at HTL Wien 3 Rennweg in the 2026/27 school year, project number 3R ME 27 07.
Work packages
The work breakdown structure splits the project into five blocks with 20 milestones in total.
Removing the combustion engine, designing the mounts for motor and controller, rebuilding the frame in CAD, small parts, manufacturing and assembly.
Selecting the electric motor, calculating the output sprocket, choosing cells and BMS, designing the pack in CAD, spot-welding the cell assembly and completing the pack.
Selecting the microcontroller, programming the motor control, integrating sensors, testing the control logic and fine-tuning.
Concept and programming of the user interface, integrating the handlebar display, adjustable riding modes, GPS and wheelie control.
Research and concept, the thesis proposal, continuous documentation, final documentation and the presentation to an industry audience.
A GPS system that sends live data to the display, and a wheelie control that stops the bike from flipping backwards under hard acceleration.
Progress
We document every step in public – for our supervisors, for our partners and for anyone who wants to follow the build.
2 of 20 milestones reached · as of September 2026
Goals, work breakdown structure, risk analysis and budget.
This site – from here on it grows with the project.
The frame gets scanned and rebuilt in CAD – the basis for every bracket that follows.
The team
We are students of class 5AM, Department of Mechatronics at HTL Wien 3 Rennweg. Each of us contributes around 300 working hours.
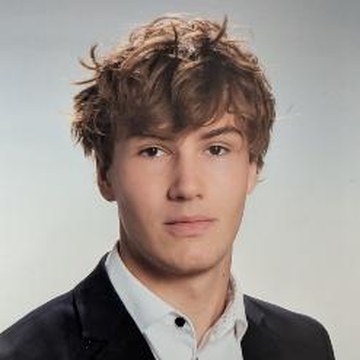
Project lead · Mechanical design
3D scanning and CAD modelling of the frame, design and manufacture of the mounts for motor, controller and battery pack.
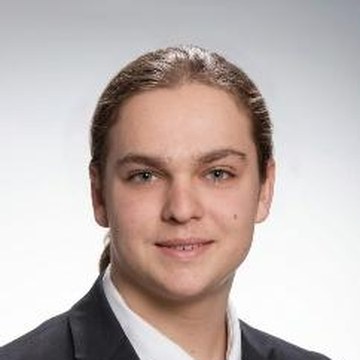
Deputy project lead · Electronics
Calculating the output sprocket, sizing and building the battery pack, selecting the BMS, commissioning and testing.
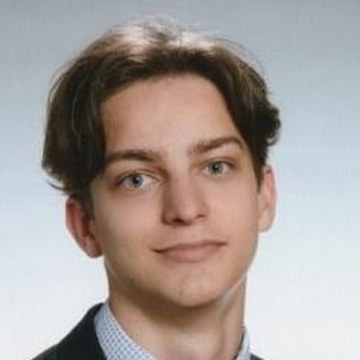
Software
Programming the motor controller, the display showing speed and remaining energy, adjustable riding modes, GPS and wheelie control.
Supervision: Ewald Cekan (lead) · Martin Meschik (deputy) · Martin Sommer (individual supervision) · Nikolaus Baumgartinger (head of department)
Partners
Battery pack, motor, controller and small parts add up to roughly 7,000 euros. According to plan the project is financed largely or entirely by sponsors – whatever stays open, the three of us split evenly.
Everyone supporting us is listed on the partners page, together with what they contribute.